
Archenaux Robotics: An Interesting New Approach to Hull Care and Marine Robotics
At Ilios Remote Sensing, we spend a lot of time looking at technologies that can improve how vessels and marine infrastructure are inspected, documented and maintained.
One company we've recently been talking with is Archenaux Robotics, which is developing robotic systems for hull cleaning, inspection, 3D mapping and other underwater work.
What caught our attention is that they're not looking at hull cleaning as an isolated task. They're combining the physical robot with cameras, sonar, mapping and increasingly autonomous operation.
Starting with a Very Old Maritime Problem
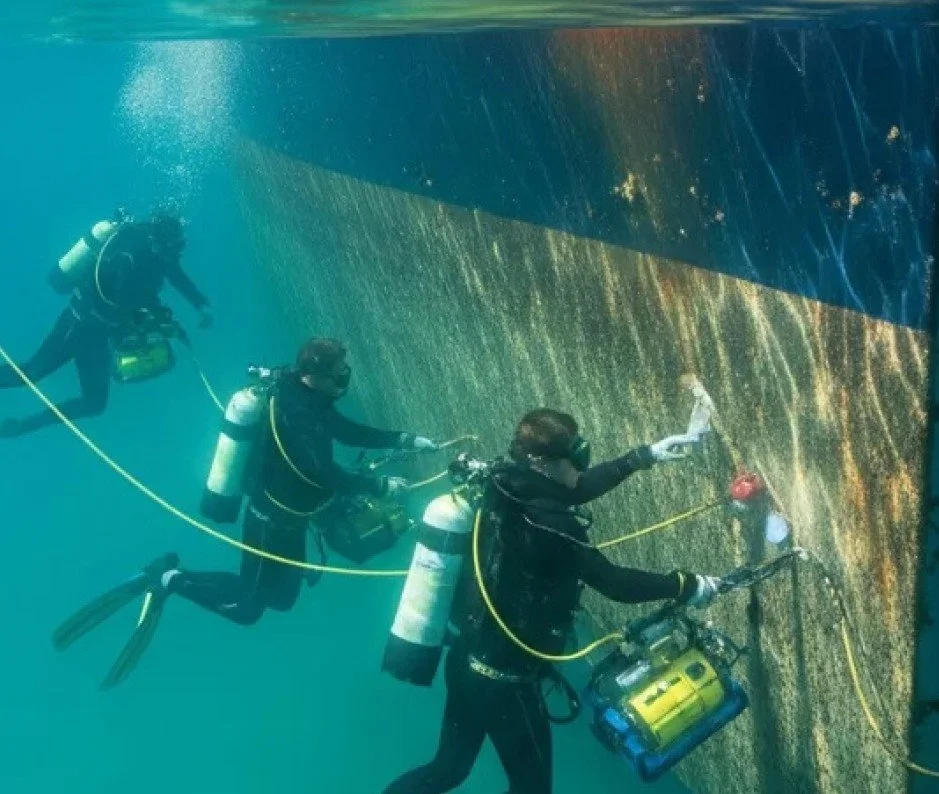
Biofouling isn't new. Marine growth increases hull resistance, affects vessel efficiency and eventually means cleaning, maintenance and downtime.
Archenaux's Archelon system approaches this as an ongoing hull-care problem rather than something that only gets addressed once fouling becomes severe.
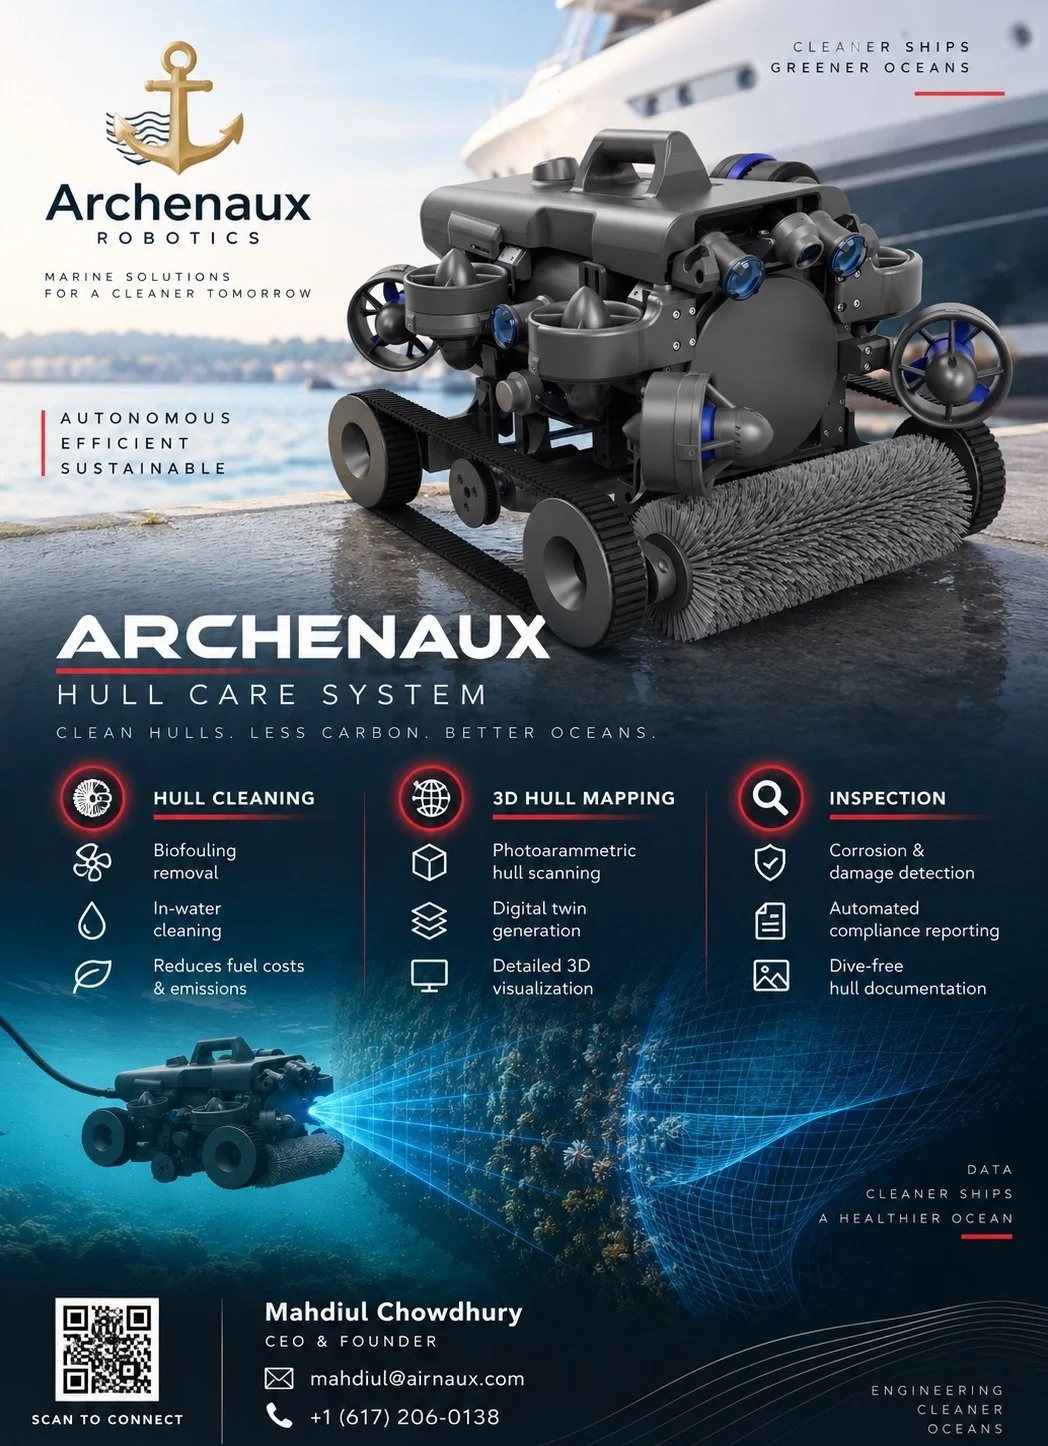
The robot is being designed around hull cleaning and maintenance, with modular cleaning equipment for different surfaces and fouling conditions. But it also incorporates inspection and data collection.
Cleaning the Hull—and Learning About It
This is where the technology gets particularly interesting to us.
Archenaux is working on 3D hull mapping, digital-twin generation and detailed visualization alongside the cleaning operation. The inspection side is intended to identify hull condition and damage and generate reports. Their development material also describes predictive maintenance and cleaning optimization as longer-term objectives.
In other words, the robot doesn't necessarily have to be thought of simply as an underwater cleaning machine.
Each time a system travels over a hull, there's an opportunity to inspect it, locate what was observed, document it and eventually compare those observations over time.
That's an area where we see some interesting overlap with the work we already do at Ilios in reality capture, 3D documentation and maritime inspection.
It's Already Getting Wet
Archenaux isn't working entirely in renderings and simulation.
The company has built and tested its Archelon prototypes underwater. The company is looking for interested parties to demonstrate their technology. For those interested, reach out to Mahdiul Chowdhury.
Beyond Hulls
Archenaux is also exploring a rather different amphibious platform.
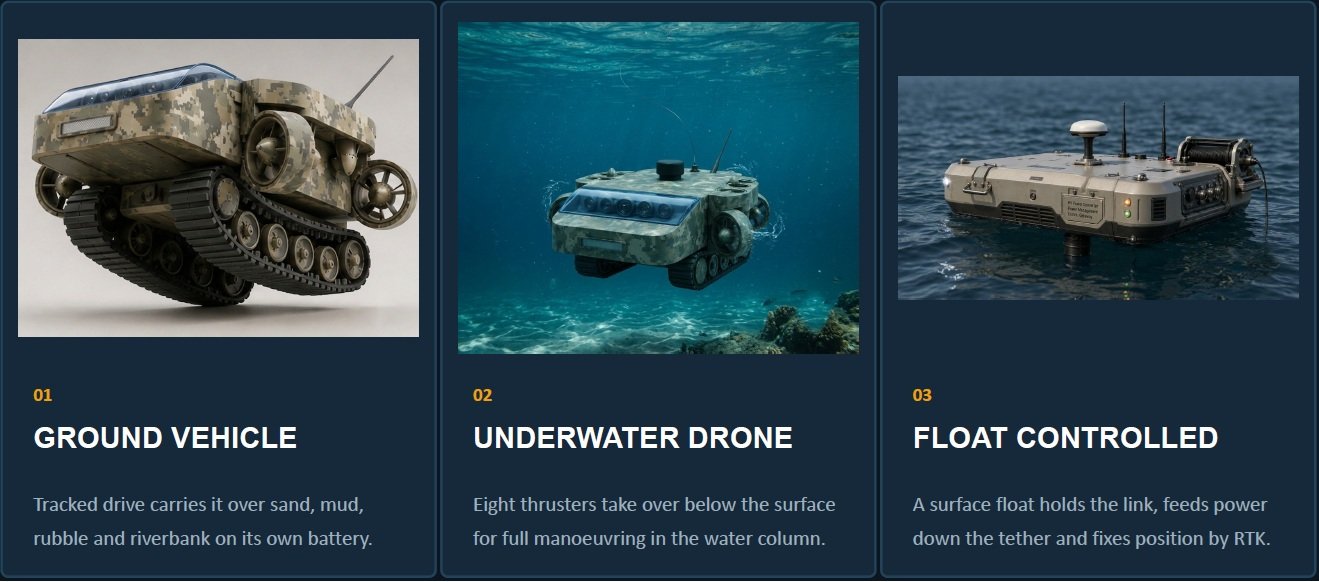
The concept is a single unmanned vehicle that can drive across land, enter the water, operate underwater and work on the seabed. A surface float can provide power, communications and positioning.
Potential applications include inspecting quay walls, piles, intakes and slipways, as well as shallow-water work and operations in flooded or otherwise difficult environments.
Where Could This Go?
That's really the reason we're interested in Archenaux.
Hull cleaning is useful by itself. But combining robotics + inspection + mapping + repeatable data collection opens up much more interesting possibilities.
A robot that routinely works on a hull or underwater structure could potentially build a history of that asset: where fouling occurred, what was cleaned, what condition was observed and what changed between inspections.
For Ilios, that's a natural area to explore. Our work is centered around capturing physical assets accurately and turning those measurements into useful documentation. Archenaux is approaching some of the same problems from the underwater robotics side.
We're looking forward to seeing where their technology goes—and exploring where our two companies might be able to work together.